Day 36 — Cross-embodiment skill transfer / sim-to-real under honest contact labels: EmbodimentSensorProvenanceRegistry / CrossEmbodimentForceRetargeter / MeasuredLabelTransferGate / SimToRealContactHonestyBridge / TransferChangeSetBinder / CrossEmbodimentSkillTransferAdmissionGate under DexterousSkillCaptureAdmissionGate + TelepresenceAdmissionGate + RemoteTeleopAdmissionGate + FleetSharedControlAdmissionGate + SharedControlAdmissionGate + CollaborativeWorkspaceAdmissionGate + proximity + zone attestation + supervisor + logging + canary + HIL + fleet + fleet-canary + incident + forensics/reopen + change-management + maintenance + thermal + energy gates
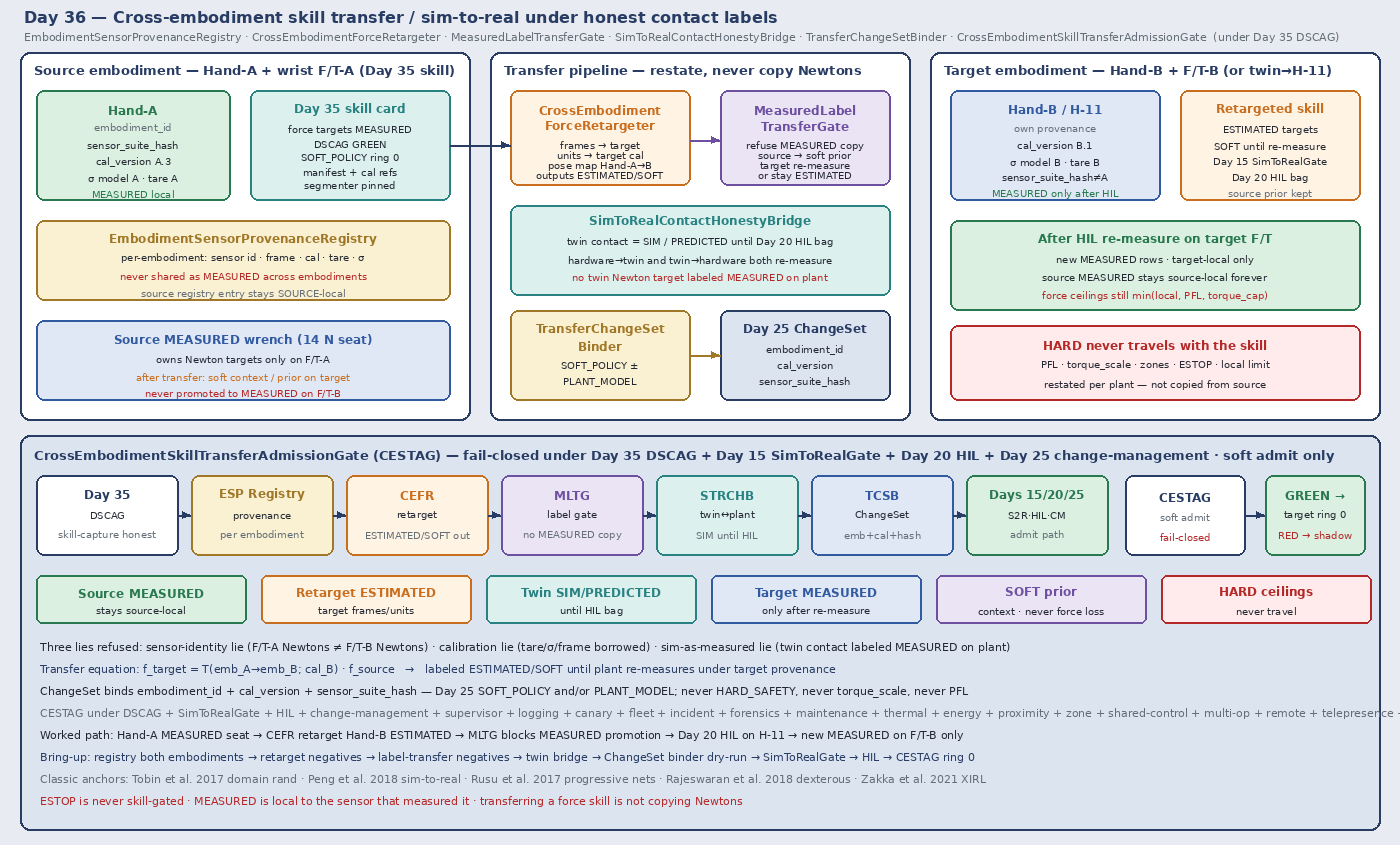
Day 15 made closed-loop learned policies soft writers behind SimToRealGate. Day 18 owns the rule that labels refuse soft→MEASURED. Day 20 owns HIL bags that re-measure the plant. Day 25 owns ChangeSets — SOFT_POLICY, PLANT_MODEL, CALIBRATION, and the HARD classes that soft layers may never write. Day 05 owns torque_scale forever. Day 29 owns HARD PFL ceilings. Day 30 owns CrossSiteZoneConfigGate. Day 34 owns contact truth labels at capture. Day 35 owns DemoHonestySegmenter / MeasuredForceLabelGate / SoftContextBagSchema / SkillCaptureHygieneGate / DemoToPolicyValidator / DexterousSkillCaptureAdmissionGate (DSCAG) — the skill that exists today was admitted under honest labels on one embodiment.
Day 35 left you with a skill that seats connector J3 under MEASURED wrist F/T on Hand-A. The obvious next move is the one every lab makes: run it on Hand-B, or on the twin, or on unit H-11 with a different F/T. That is cross-embodiment transfer and sim-to-real, and on a force skill it is where three new lies enter:
- Sensor-identity lie. A Newton measured on F/T-A is not a Newton measured on F/T-B. Different load-cell, different mounting compliance, different saturation curve, different frame. Copying the number into the target skill’s force column and calling it MEASURED is laundering provenance across hardware.
- Calibration lie. Even “the same” sensor model has a different tare, a different cal version, a different σ model after thermal soak and Day 26 drift. Borrowing source tare or source σ onto the target embodiment makes ESTIMATED look like MEASURED without a measurement.
- Sim-as-measured lie. The twin’s contact wrench is a model. Labeling it MEASURED on the plant — or labeling a plant MEASURED row as if the twin produced it — collapses the Day 15 / Day 20 distinction that
SimToRealGateand HIL exist to protect.
Today owns EmbodimentSensorProvenanceRegistry / CrossEmbodimentForceRetargeter / MeasuredLabelTransferGate / SimToRealContactHonestyBridge / TransferChangeSetBinder / CrossEmbodimentSkillTransferAdmissionGate. The question is: when a Day 35 captured skill moves to a different hand, wrist F/T, tactile suite, or twin↔hardware, how do you keep each embodiment’s sensor provenance, calibration, and σ local; re-state force targets in the target embodiment’s frames and units without ever promoting source MEASURED onto target sensors; keep twin contact labeled SIM/PREDICTED until a Day 20 HIL bag re-measures; package the transfer as Day 25 ChangeSets; and admit only through Day 35 DSCAG + Day 15 SimToRealGate + Day 20 HIL + Day 25 change-management — without raising Day 29 PFL, writing Day 05 torque_scale, or bypassing CrossSiteZoneConfigGate?
Transferring a force skill is not copying Newtons
The core split of the series, applied to embodiment change:
- MEASURED is local to the sensor that measured it. Day 34 CFTS and Day 35 MFLG already said this inside one bag. Across embodiments it is absolute: source MEASURED may become a soft prior or soft context on the target; it may never become MEASURED on a different sensor suite.
- A retargeted target is ESTIMATED or SOFT until the target plant re-measures. Frames, units, and kinematics can be transformed with the target’s calibration; the contact truth cannot. The retargeter’s output is a proposal the target embodiment must earn.
- HARD ceilings never travel with the skill. Robot-side local limits, Day 29 PFL, Day 05
torque_scale, Day 30 zones, and Day 17 ESTOP are plant owners. A transferred skill inherits the target plant’s ceilings, not a copy of the source’s.
So the honest transfer labels are:
| Quantity after transfer | Label on target | May become | Must never become |
|---|---|---|---|
| Source MEASURED wrench (F/T-A) | Soft prior / context | Conditioning feature; initialization prior | MEASURED on F/T-B or twin |
| Retargeted wrench in target frames/units | ESTIMATED ±σ_retarget | Soft skill target until HIL; pose/force proposal | MEASURED without plant re-measure |
| Twin contact wrench (no HIL bag) | SIM / PREDICTED | Twin eval only; Day 15 path | MEASURED on hardware |
| Twin contact after Day 20 HIL pairing | SIM on twin side; MEASURED on plant side of the bag | Paired traces for SimToRealGate | A single MEASURED label spanning both |
| Target F/T-B re-measure during HIL / canary | MEASURED (target-local) | Newton targets for target skill card | Back-labeled onto source bags |
| Source calibration / tare / σ model | Source-local metadata | Provenance of the prior | Target cal / tare / σ |
| Target calibration / tare / σ model | Target-local | Retarget transform inputs; MEASURED eligibility | Something the skill “brings” from source |
Robot-side local limit / PFL / torque_scale / zones | HARD (target plant) | Constraints the transferred skill is validated against | Values copied from source ChangeSets |
The first rule of today: a force skill may move; its MEASURED labels may not. Retarget into the target’s frames, then re-measure on the target — or stay ESTIMATED forever.
| Layer | Owns | Must not own |
|---|---|---|
| Day 35 DSCAG + skill card | Source skill admitted under honest labels on source embodiment | Target MEASURED rows; target HARD ceilings |
EmbodimentSensorProvenanceRegistry | Per-embodiment sensor identity, frame, cal version, tare policy, σ model, sensor_suite_hash | Sharing MEASURED across embodiments; silent cal reuse |
CrossEmbodimentForceRetargeter | Frame/unit/pose re-expression into target calibration; ESTIMATED/SOFT outputs | Emitting MEASURED; writing HARD ceilings |
MeasuredLabelTransferGate | Refusal of source MEASURED → target MEASURED promotion | Repairing labels “so transfer passes” |
SimToRealContactHonestyBridge | Twin↔plant pairing; SIM/PREDICTED until HIL re-measure | Twin-as-MEASURED on plant; plant-as-SIM without marking |
TransferChangeSetBinder | Day 25 SOFT_POLICY / PLANT_MODEL packaging with embodiment_id, cal_version, sensor_suite_hash | HARD_SAFETY ChangeSets; torque_scale; PFL |
CrossEmbodimentSkillTransferAdmissionGate | Composed fail-closed soft admit under DSCAG + Day 15 + Day 20 + Day 25 | Clearing supervisor; dual-writing ESTOP / torque_scale |
| Days 05 / 17 / 29 / 30 | Torque, kill-chain, PFL, zone | Being outranked by a transferred skill |
Core thesis: cross-embodiment and sim-to-real transfer of a force skill is re-stating the skill under a new plant’s sensor provenance. MEASURED is local to the sensor that measured it; sim and cross-hand transfers arrive as ESTIMATED/SOFT until the target embodiment re-measures; HARD ceilings (PFL, torque_scale, zones, ESTOP) never travel with the skill.
Three lies when you port a skill
1. Sensor-identity lie. Hand-A’s wrist F/T reports 14 N at seat. Hand-B’s F/T, different serial and mount, would have reported something else for the same physical contact — different compliance in the flange, different crosstalk, different saturation onset. Treating 14 N as a MEASURED target on Hand-B teaches the policy a number that was never measured there. Domain-randomization papers (Tobin et al., 2017) and sim-to-real force work both assume you know which distribution a sample came from; copying across sensors erases that.
2. Calibration lie. Day 26 already told you actuators and sensors drift. Day 25 CALIBRATION ChangeSets pin tare and cal artifacts. A transfer that applies source tare offsets or source σ to target samples is a silent cal write. EmbodimentSensorProvenanceRegistry makes the cal version part of the embodiment identity: different cal_version → different registry entry → retarget must re-run, not reuse.
3. Sim-as-measured lie. Peng et al. (2018) and the Day 15 gate both require that sim success is not plant success. A twin wrench labeled MEASURED on the plant, or a plant bag whose contact column was filled from the twin, collapses the bridge. SimToRealContactHonestyBridge keeps twin contact SIM/PREDICTED until a Day 20 HIL bag pairs plant MEASURED with twin traces under the same episode id.
The fix is not a better transform. It is refusing to promote labels across sensor suites, and admitting transfer only as ChangeSets that name the target embodiment.
EmbodimentSensorProvenanceRegistry: MEASURED stays local
EmbodimentSensorProvenanceRegistry (ESPR) is the authoritative map from embodiment_id to the sensor suite that may produce MEASURED contact for that embodiment. It does not measure anything; it refuses identity confusion.
| Field | Meaning |
|---|---|
embodiment_id | Stable id: unit + hand model + serial + end-effector role (e.g. H-07/Hand-A/EE_R) |
sensor_suite_hash | Hash of sensor identities, frames, bus addresses, firmware |
ft_sensor_id / tactile_suite_id | Hardware identity; changing it changes the hash |
frame_id | Wrench and pose frames (wrist, tool, taxel map) |
cal_version | Day 25 CALIBRATION ChangeSet id currently binding |
tare_policy | When tare is valid; max tare age; who may tare |
sigma_model_id | Per-axis σ model version (temperature, velocity bands) |
may_emit_measured | True only for this suite on this embodiment |
Rules:
- One MEASURED owner per contact channel per embodiment. F/T-A cannot emit MEASURED for Hand-B’s skill card. Twin suites have
may_emit_measured: falsefor plant skill cards. - Hash is content-addressed. Swap an F/T, reflash firmware, or change the tool frame → new
sensor_suite_hash→ new registry entry. Old skill cards referencing the old hash do not silently bind to the new suite. - Cal version is part of identity for transfer. Retarget inputs include source and target
cal_version. A transfer ChangeSet that omits either is incomplete. - Registry is read by gates; written only by Day 25 CALIBRATION / PLANT_MODEL paths. Soft skill code never registers a sensor.
from dataclasses import dataclass

@dataclass(frozen=True)
class EmbodimentProvenance:
    embodiment_id: str
    sensor_suite_hash: str
    ft_sensor_id: str
    frame_id: str
    cal_version: str
    tare_policy: str
    sigma_model_id: str
    may_emit_measured: bool   # False for twin-only suites on plant cards

def assert_local_measured(row_embodiment: str, row_suite_hash: str, label: str, reg) -> None:
    """MEASURED rows must cite the registry entry that owns them. Pure check."""
    e = reg.get(row_embodiment)
    if label == "MEASURED":
        if not e.may_emit_measured:
            raise ValueError("SIM/twin suite cannot emit MEASURED on plant card")
        if row_suite_hash != e.sensor_suite_hash:
            raise ValueError("MEASURED suite hash mismatch — refuse cross-embodiment laundering")
CrossEmbodimentForceRetargeter: re-state, don’t copy
CrossEmbodimentForceRetargeter (CEFR) maps a source skill’s force and pose targets into the target embodiment’s frames and units using the target calibration. It never upgrades labels.
Pose / joint retarget uses the target hand kinematics (including fingertip frames if the tactile suite differs). The outputs are:
| Output | Label | Use |
|---|---|---|
| Retargeted wrench proposal | ESTIMATED ±σ_retarget | Soft skill target; Day 15 twin eval; never force-loss MEASURED |
| Retargeted pose / aperture | ESTIMATED or SOFT | Kinematic prior; still validated under target local limits |
| Mapping metadata | — | source_embodiment_id, target_embodiment_id, both cal versions, both suite hashes, retargeter version |
Rules:
- Target cal only for target quantities. Source cal explains the prior; it does not transform into target Newtons without target cal.
- σ always grows. Retarget uncertainty is at least source σ plus cal uncertainty plus mapping uncertainty. A retarget that shrinks σ is a bug.
- No MEASURED emission. CEFR’s wire type forbids
label: MEASURED. - Versioned and pure. Same inputs + retargeter version → byte-identical outputs; version pinned in the ChangeSet.
def retarget(skill_src, emb_src, emb_tgt, cfg) -> "RetargetBundle":
    """Pure. Emits ESTIMATED/SOFT only. Refuses if either registry entry missing."""
    if emb_src.sensor_suite_hash == emb_tgt.sensor_suite_hash and emb_src.cal_version == emb_tgt.cal_version:
        raise ValueError("same suite+cal — not a cross-embodiment transfer; use Day 35 path")
    f_tgt, sig = transform_wrench(skill_src.force_targets, emb_src, emb_tgt, cfg)
    # σ inflation mandatory
    sig = inflate_sigma(sig, emb_tgt.sigma_model_id, cfg.map_sigma)
    return RetargetBundle(
        wrench=f_tgt, sigma=sig, label="ESTIMATED",
        pose=transform_pose(skill_src.pose_targets, emb_src, emb_tgt),
        source_ref=emb_src.embodiment_id, target_ref=emb_tgt.embodiment_id,
        cal_src=emb_src.cal_version, cal_tgt=emb_tgt.cal_version,
        suite_src=emb_src.sensor_suite_hash, suite_tgt=emb_tgt.sensor_suite_hash,
        retargeter_version=cfg.version,
        forbid_measured=True)
MeasuredLabelTransferGate: source MEASURED never becomes target MEASURED
MeasuredLabelTransferGate (MLTG) is the Day 35 MeasuredForceLabelGate idea applied to transfer, not to demo rows. It is a pure filter:
| Proposal | Verdict |
|---|---|
| Copy source MEASURED wrench into target skill force column as MEASURED | Refused |
| Use source MEASURED as soft prior / context feature on target | Allowed; may_regress_force_against: false unless target HIL re-measured the same episode |
| Promote CEFR ESTIMATED → MEASURED without HIL bag | Refused |
| Promote twin SIM/PREDICTED → MEASURED on plant | Refused (bridge owns this) |
| After Day 20 HIL: plant F/T-B MEASURED rows on target card | Allowed; source rows remain source-local; no back-label onto source bags |
| ESTIMATED retarget used as Newton target in training loss on target | Only with commissioning flag + σ_retarget budget; stays ESTIMATED in manifest |
MLTG does not invent HIL. It only checks that any MEASURED row on a target skill card cites a target registry entry and a plant measurement event (capture demo on target, or HIL re-measure bag).
SimToRealContactHonestyBridge: twin contact stays SIM until HIL
SimToRealContactHonestyBridge (STRCHB) pairs twin and hardware under Day 15 / Day 20 discipline:
| Direction | Twin label | Plant label | Allowed claim |
|---|---|---|---|
| Twin → hardware (no HIL) | SIM / PREDICTED | — | Twin eval only |
| Twin → hardware (with HIL bag) | SIM on twin half | MEASURED on plant half | Paired divergence metrics; plant MEASURED may train target |
| Hardware → twin | — | MEASURED (source or target) | Twin replay for regression; twin contact still SIM |
| Hardware → hardware (cross hand) | — | Source MEASURED + target ESTIMATED until target HIL/demo | MLTG path; no twin required but Day 15 still runs |
The bridge refuses a single column that mixes twin and plant without side: TWIN|PLANT and refuses any plant MEASURED whose sensor_suite_hash is the twin’s.
TransferChangeSetBinder: Day 25 packaging
TransferChangeSetBinder (TCSB) wraps an accepted retarget + bridge result as Day 25 ChangeSets:
| ChangeSet class | Carries | Must not carry |
|---|---|---|
SOFT_POLICY | Retargeted skill card, retargeter version, MLTG config, source skill id, ESTIMATED/MEASURED row counts | PFL, torque_scale, zone geometry, ESTOP |
PLANT_MODEL | Target kinematics / compliance notes used by CEFR, twin contact model id for STRCHB | HARD_SAFETY; silent cal |
CALIBRATION (prerequisite, not written by TCSB) | Target cal_version already admitted | Invented by the skill transfer |
Every bound ChangeSet must include:
embodiment_id(target)cal_version(target)sensor_suite_hash(target)source_embodiment_id,source_suite_hash,source_cal_versionretargeter_version,bridge_version- refs to Day 15 SimToRealGate result and Day 20 HIL bag (or explicit
hil: none→ plant MEASURED forbidden)
CrossEmbodimentSkillTransferAdmissionGate: composition under DSCAG
CrossEmbodimentSkillTransferAdmissionGate (CESTAG) admits a transferred skill onto a target embodiment and fails closed unless:
- Day 35
DexterousSkillCaptureAdmissionGateGREEN for the source skill (honest capture still holds) - ESPR entries present and unconflicting for source and target; hashes match ChangeSet
- CEFR version pinned; outputs ESTIMATED/SOFT only; σ inflated
- MLTG clean: no source MEASURED promoted; target MEASURED only with plant events
- STRCHB: twin path labeled SIM/PREDICTED; HIL bag present if claiming plant MEASURED
- Day 15
SimToRealGateGREEN for target embodiment class - Day 20 HIL GREEN when leaving shadow on hardware
- Day 25 ChangeSets bound (
SOFT_POLICY±PLANT_MODEL); no HARD_SAFETY writes - Day 22 fleet canary GREEN for this skill × target embodiment class; Day 23 no open incident; Day 24 reopen GREEN
- Day 26: no open recalibration on target F/T / hand; Day 27 / Day 28 admits GREEN
- Day 34 TAG / Day 33 RTAG / … stack still GREEN where telepresence re-capture is used on target
Soft admit blocker only — CESTAG does not publish JointCommand, does not clear ESTOP, does not write Day 05, does not raise PFL, does not bypass CrossSiteZoneConfigGate. Demotions always flow.
A worked transfer example
Source: SITE_A unit H-07, Hand-A, wrist F/T-A, Day 35 skill seat-J3 DSCAG GREEN. Target: SITE_C unit H-11, Hand-B (different kinematics), wrist F/T-B (different serial), attested map_version = 17. Also evaluate twin twin-H-11 before HIL.
| Step | MEASURED / HARD | Soft / ESTIMATED | Verdict |
|---|---|---|---|
| Source skill on H-07 | F/T-A MEASURED seat 14 N | Soft context from Day 35 | Source card unchanged |
| ESPR lookup | Suite hashes A ≠ B | — | Transfer required; not a same-suite deploy |
| CEFR retarget | — | ESTIMATED, σ↑ | Proposal only |
| Engineer tries to paste 14 N as MEASURED on H-11 | — | — | MLTG refused |
| Twin sweep | Twin contact SIM | ESTIMATED skill output | SimToRealGate runs; not plant MEASURED |
| HIL on H-11 | F/T-B MEASURED on re-measure ticks | Unre-measured torque axes stay ESTIMATED | Target card may use new MEASURED rows only |
| Request to raise H-11 local limit to match H-07 | Local limit HARD | Request | Refused; validate under target ceiling |
ChangeSet missing sensor_suite_hash | — | — | TCSB incomplete; CESTAG RED |
| CESTAG admit | Target ceilings bind | SOFT_POLICY ring 0 | GREEN; source MEASURED never on H-11 card |
| Co-worker ESTOP during canary | Day 17 | Skill running | Kill-chain; demote; Day 23 ticket |
Ownership conflicts
| Conflict | Winner | Behavior |
|---|---|---|
| Source MEASURED vs target MEASURED claim | MLTG + ESPR | Source stays source-local; target needs plant re-measure |
| CEFR ESTIMATED wants MEASURED | MLTG | Refused without HIL/demo on target suite |
| Twin SIM vs plant MEASURED in one column | STRCHB | Split sides; refuse mixed unlabeled column |
| Source cal applied to target samples | ESPR / Day 25 CALIBRATION | Target cal only; source cal is prior metadata |
| Same skill, new F/T serial, old suite hash in ChangeSet | ESPR hash | RED; re-bind ChangeSet |
| Transferred skill vs target local limit | Target local limit | Validate under target; never copy source limit |
Eval fails → raise PFL / torque_scale | Days 29 / 05 | Refused; smaller envelope or RED |
Unattested map_version on target site | CrossSiteZoneConfigGate | Refused |
| Soft transfer vs Day 17 ESTOP | Day 17 | Kill-chain; demote |
Shared API
ESPR, CEFR, MLTG, STRCHB, TCSB run offline / on the fleet admission path over skill cards and bags; CESTAG publishes on the fleet admission path. Nothing here enters the cyclic loop; on-unit fences still run at control rate on the target plant.
BusHeader:
  t_mono
  seq
  clock_domain
  age_ms
  producer_id

EmbodimentProvenance ⊇ BusHeader:          # EmbodimentSensorProvenanceRegistry
  embodiment_id
  sensor_suite_hash
  ft_sensor_id, tactile_suite_id
  frame_id
  cal_version
  tare_policy
  sigma_model_id
  may_emit_measured
  forbid:
    cross_emit_measured: true
    soft_register_sensor: true

RetargetBundle ⊇ BusHeader:                # CrossEmbodimentForceRetargeter
  source_embodiment_id, target_embodiment_id
  source_suite_hash, target_suite_hash
  cal_src, cal_tgt
  wrench_n_nm[6]
  sigma_n_nm[6]            # inflated
  pose_target
  label                    # ESTIMATED | SOFT — never MEASURED
  retargeter_version
  forbid:
    emit_measured: true
    shrink_sigma: true

LabelTransferDecision ⊇ BusHeader:         # MeasuredLabelTransferGate
  proposal_ref
  verdict                  # ALLOW_ESTIMATED | ALLOW_SOFT_PRIOR | ALLOW_TARGET_MEASURED | REFUSE
  refuse_reason            # SOURCE_MEASURED_COPY | NO_HIL | SUITE_MISMATCH | TWIN_AS_MEASURED | ...
  may_regress_force_against: bool

ContactHonestyPair ⊇ BusHeader:            # SimToRealContactHonestyBridge
  episode_id
  twin_side:
    label                  # SIM | PREDICTED
    suite_hash_twin
  plant_side:
    label                  # MEASURED | ESTIMATED | NONE
    suite_hash_plant
  hil_bag_ref              # required if plant_side.label == MEASURED from transfer path
  forbid:
    mixed_unlabeled_column: true
    twin_measured_on_plant: true

TransferChangeSet ⊇ BusHeader:             # TransferChangeSetBinder
  classes                  # SOFT_POLICY | PLANT_MODEL
  target_embodiment_id
  cal_version
  sensor_suite_hash
  source_embodiment_id
  source_suite_hash, source_cal_version
  retargeter_version, bridge_version
  sim_to_real_gate_ref
  hil_ref                  # or hil: none
  forbid:
    hard_safety_class: true
    write_torque_scale: true
    raise_pfl: true

CrossEmbodimentSkillTransferAdmissionGate ⊇ BusHeader:
  fail_closed: true
  soft_admit_blocker_only: true
  status                   # RED | YELLOW | GREEN
  require:
    dexterous_skill_capture_admission_green: true   # Day 35 DSCAG source
    embodiment_registry_bound: true
    retarget_estimated_or_soft_only: true
    measured_label_transfer_clean: true
    sim_to_real_contact_honesty: true
    sim_to_real_gate_green: true                     # Day 15
    hil_green_if_plant_measured: true                # Day 20
    transfer_changeset_bound: true                   # Day 25
    fleet_canary_gate_green: true                    # Day 22
    no_open_incident_on_unit: true                   # Day 23
    canary_reopen_gate_green: true                   # Day 24
    no_open_recalibration_on_target: true            # Day 26
    thermal_admission_gate_green: true               # Day 27
    energy_admission_gate_green: true                # Day 28
    telepresence_stack_green_if_recapture: true      # Days 30–34
    cross_site_zone_config_green: true
    human_safety_admission_green: true
    supervisor_armed: true
    estop_pairing: true
    day05_binding: true
  blocks: promotions_only
  forbid:
    joint_command: true
    dual_write_torque_scale: true
    clear_supervisor_stage: true
    write_estop: true
    raise_pfl_from_transfer: true
    bypass_cross_site_zone_config_gate: true
    write_hard_safety_changeset: true
    promote_source_measured_to_target: true

# Unchanged owners
DexterousSkillCaptureAdmissionGate (Day 35): honest capture on source embodiment
TelepresenceAdmissionGate (Day 34) · RemoteTeleopAdmissionGate (Day 33)
FleetSharedControlAdmissionGate (Day 32) · SharedControlAdmissionGate (Day 31)
CollaborativeWorkspaceAdmissionGate (Day 30) · CrossSiteZoneConfigGate
HumanSafetyAdmissionGate (Day 29)
SimToRealGate (Day 15) · HIL farm (Day 20) · Change management (Day 25)
SupervisorState (Day 17): ESTOP · kill-chain · stage · monitors
BmsState / PowerState (Day 05): torque_scale · contactor · UVLO · STO
  accepts_requests_from_soft_layer: false
Config
A starting configuration for this series. Every number is a policy you re-derive on your twin and bench, not a literature constant:
cross_embodiment_transfer:
  registry:
    require_fields: [embodiment_id, sensor_suite_hash, ft_sensor_id, frame_id, cal_version, tare_policy, sigma_model_id]
    twin_may_emit_measured_on_plant_card: false
    hash_includes: [sensor_ids, frames, firmware, bus_addrs]
  retargeter:
    version: cefr-1.1.0
    output_labels: [ESTIMATED, SOFT]
    forbid_measured: true
    sigma_inflation: [source_sigma, target_cal_sigma, map_sigma]
    map_sigma_n: 0.5
    same_suite_same_cal: refuse_as_transfer   # use Day 35 deploy path instead
  measured_label_transfer_gate:
    refuse: [SOURCE_MEASURED_COPY, TWIN_AS_MEASURED, ESTIMATED_TO_MEASURED_WITHOUT_HIL]
    allow_soft_prior_from_source_measured: true
    soft_prior_may_regress_force_against: false
    estimated_force_targets: false            # commissioning; Day 25 GATE_THRESHOLD to enable
    sigma_retarget_budget_n: 1.2
    target_measured_requires: [plant_event, matching_suite_hash, matching_cal_version]
  sim_to_real_bridge:
    twin_contact_labels: [SIM, PREDICTED]
    plant_measured_requires_hil_bag: true
    refuse_mixed_unlabeled_column: true
    pair_episode_id: required
  changeset_binder:
    classes: [SOFT_POLICY, PLANT_MODEL]
    require_fields: [target_embodiment_id, cal_version, sensor_suite_hash, source_embodiment_id, retargeter_version]
    forbid_classes: [HARD_SAFETY]
  admission:
    gate: CrossEmbodimentSkillTransferAdmissionGate
    under: [DexterousSkillCaptureAdmissionGate, SimToRealGate, HilFarm, ChangeManagement,
            TelepresenceAdmissionGate, RemoteTeleopAdmissionGate, FleetSharedControlAdmissionGate,
            SharedControlAdmissionGate, CollaborativeWorkspaceAdmissionGate, CrossSiteZoneConfigGate,
            HumanSafetyAdmissionGate]
    demotions_always_flow: true
  forbidden:
    raise_pfl: true
    write_torque_scale: true
    raise_local_force_limit_to_match_source: true
    bypass_cross_site_zone_config_gate: true
    copy_source_measured_as_target_measured: true
Physical ↔ digital pairing
| Physical | Digital twin / backing |
|---|---|
| Swap Hand-A for Hand-B on H-11 | New embodiment_id + sensor_suite_hash; ESPR entry; old skill card does not bind |
| Replace wrist F/T serial | New suite hash; CALIBRATION ChangeSet; retarget must re-run |
| Twin seats connector “at 14 N” | SIM/PREDICTED contact; not plant MEASURED |
| HIL run on H-11 with F/T-B | Plant MEASURED rows paired to twin SIM under one episode id |
| Source demo bag from H-07 | Remains source-local; may be soft prior only on H-11 card |
| Target site fixture survey | Attested map_version; unattested demos/transfers refused |
| Engineer pastes source Newtons into target loss | MLTG refuse; forensic note |
| Canary ESTOP on H-11 | Day 17; skill demoted; Day 23; source skill unaffected |
The twin pairing that matters most: retarget on the twin with SIM contact labels, then re-measure on the plant under HIL and prove SimToRealGate divergence stays inside budget — without ever relabeling twin contact as MEASURED on the plant card.
Bring-up sequence (before transferring a force skill)
- Days 05 and 15–35 green. Do not transfer a skill whose source capture was not DSCAG-honest.
- ESPR both embodiments. Register source and target with suite hashes, cal versions, tare policies, σ models. Twin suites marked
may_emit_measured: falseon plant cards. - CEFR negatives. Attempt MEASURED emission, σ shrinkage, and same-suite “transfer” — all refused.
- MLTG negatives. Paste source MEASURED, promote ESTIMATED without HIL, label twin as MEASURED — all refused.
- STRCHB twin path. Twin eval with SIM/PREDICTED only; refuse mixed unlabeled columns.
- Day 15 SimToRealGate on the target embodiment class with retargeted ESTIMATED skill.
- Day 20 HIL re-measure on target hardware; pair episode ids; allow MEASURED only on re-measured axes.
- TCSB dry-run. Incomplete ChangeSets (missing hash/cal), HARD_SAFETY class,
torque_scalewrite — refused. - Forbidden-request negatives. Raise PFL, copy source local limit, bypass
CrossSiteZoneConfigGate— refused and bagged. - CESTAG admit to target ring 0. Soft admit; every RED, incident, or trip demotes without waiting.
Failure gallery
| Symptom | Likely cause |
|---|---|
| Target unit presses like source Newtons but F/T-B never agreed | Source MEASURED copied into target loss |
| Twin GREEN, plant jams immediately | Twin contact labeled MEASURED; no HIL re-measure |
| σ on retargeted targets smaller than source | CEFR skipped inflation / used source cal as target |
| Skill fine after F/T swap until first contact | Suite hash not updated; old MEASURED bound to new sensor |
| ChangeSet admitted without cal_version | TCSB incomplete; CESTAG should have been RED |
| “Matched source local limit on target so seat succeeded” | HARD ceiling treated as transferable tuning |
| Source bags rewritten with target labels | Back-label across embodiments |
| Canary demoted, retrained using twin wrench as MEASURED | STRCHB bypassed |
| Learned transfer “fixed” by writing torque_scale | Soft layer wrote Day 05 |
| Cross-site transfer ignored map_version | CrossSiteZoneConfigGate bypassed |
What to freeze this week
Extend frames and your safety config with:
EmbodimentSensorProvenanceRegistry: per-embodiment sensor identity, frame, cal version, tare policy, σ model,sensor_suite_hash; MEASURED emission local; twin suites cannot MEASURED on plant cards.CrossEmbodimentForceRetargeter: re-express force/pose into target frames and units with target cal; ESTIMATED/SOFT only; σ inflated; version pinned.MeasuredLabelTransferGate: refuse source MEASURED → target MEASURED; soft prior allowed; target MEASURED only with plant events matching suite+cal.SimToRealContactHonestyBridge: twin contact SIM/PREDICTED until Day 20 HIL pairing; refuse mixed unlabeled columns; plant MEASURED stays plant-local.TransferChangeSetBinder: Day 25SOFT_POLICY±PLANT_MODELwithembodiment_id,cal_version,sensor_suite_hash; never HARD_SAFETY / PFL /torque_scale.CrossEmbodimentSkillTransferAdmissionGatefail-closed under Day 35 DSCAG + Day 15 SimToRealGate + Day 20 HIL + Day 25 change-management + Days 22–34 stack; soft admit blocker only; no dual-write of ESTOP ortorque_scale; no transfer raises PFL; MEASURED never crosses sensor suites.- ESTOP is never skill-gated. Transferring a force skill is not copying Newtons.
The lesson isn’t “domain-adapt the weights and deploy.” It’s that a force skill moves by re-statement under the target plant’s sensor provenance: source MEASURED stays source-local, retarget arrives ESTIMATED/SOFT, twin contact stays SIM until HIL re-measures, ChangeSets name the embodiment, and HARD ceilings never hitch a ride.
Further reading
Look these up by title; they are classic sources for today’s cross-embodiment, sim-to-real, and domain-adaptation arguments:
- J. Tobin et al., “Domain randomization for transferring deep neural networks from simulation to the real world,” IROS 2017.
- X. B. Peng, M. Andrychowicz, W. Zaremba, and P. Abbeel, “Sim-to-real transfer of robotic control with dynamics randomization,” ICRA 2018.
- A. A. Rusu et al., “Sim-to-real robot learning from pixels with progressive nets,” CoRL 2017.
- A. Rajeswaran et al., “Learning complex dexterous manipulation with deep reinforcement learning and demonstrations,” RSS 2018.
- Y. Chebotar et al., “Closing the sim-to-real loop: Adapting simulation randomization with real world experience,” ICRA 2019.
- OpenAI et al., “Solving Rubik’s Cube with a robot hand,” arXiv 2019 — sim-to-real dexterous transfer.
- K. Zakka, A. Zeng, P. Florence, J. Tompson, J. Bohg, and D. Dwibedi, “XIRL: Cross-embodiment inverse reinforcement learning,” CoRL 2021.
- I. Radosavovic et al., “Real-world robot learning with masked visual pre-training,” CoRL 2022.
- A. Yu, A. Foote, R. Mooney, and R. Martín-Martín, “Natural language can help bridge the sim2real gap,” RSS 2024.
- O. Kroemer, S. Niekum, and G. Konidaris, “A review of robot learning for manipulation: Challenges, representations, and algorithms,” Journal of Machine Learning Research, 2021.
- N. Hogan, “Impedance control: An approach to manipulation,” ACC / ASME JDSMC 1985 — why force targets are plant-relative.
- M. H. Raibert and J. J. Craig, “Hybrid position/force control of manipulators,” ASME JDSMC 1981.
Next
Day 37+ — Fleet skill library / multi-unit skill catalog under embodiment-honest admission: versioned skill cards keyed by embodiment_id + sensor_suite_hash, queryable across the fleet with canary cohorts per embodiment class, no cross-suite MEASURED reuse, catalog promote/demote as Day 25 ChangeSets through Day 36 CESTAG + Day 35 DSCAG — without raising Day 29 PFL, writing Day 05 torque_scale, or bypassing CrossSiteZoneConfigGate, under the same gates (supervisor + logging + canary + HIL + fleet + fleet-canary + incident + forensics/reopen + change-management + maintenance + thermal + energy + proximity + zone attestation + shared-control + multi-operator + remote-teleop + telepresence + skill-capture + cross-embodiment transfer admission).