Day 14 — Learned residuals / richer scene graphs on the affordance→schedule stack
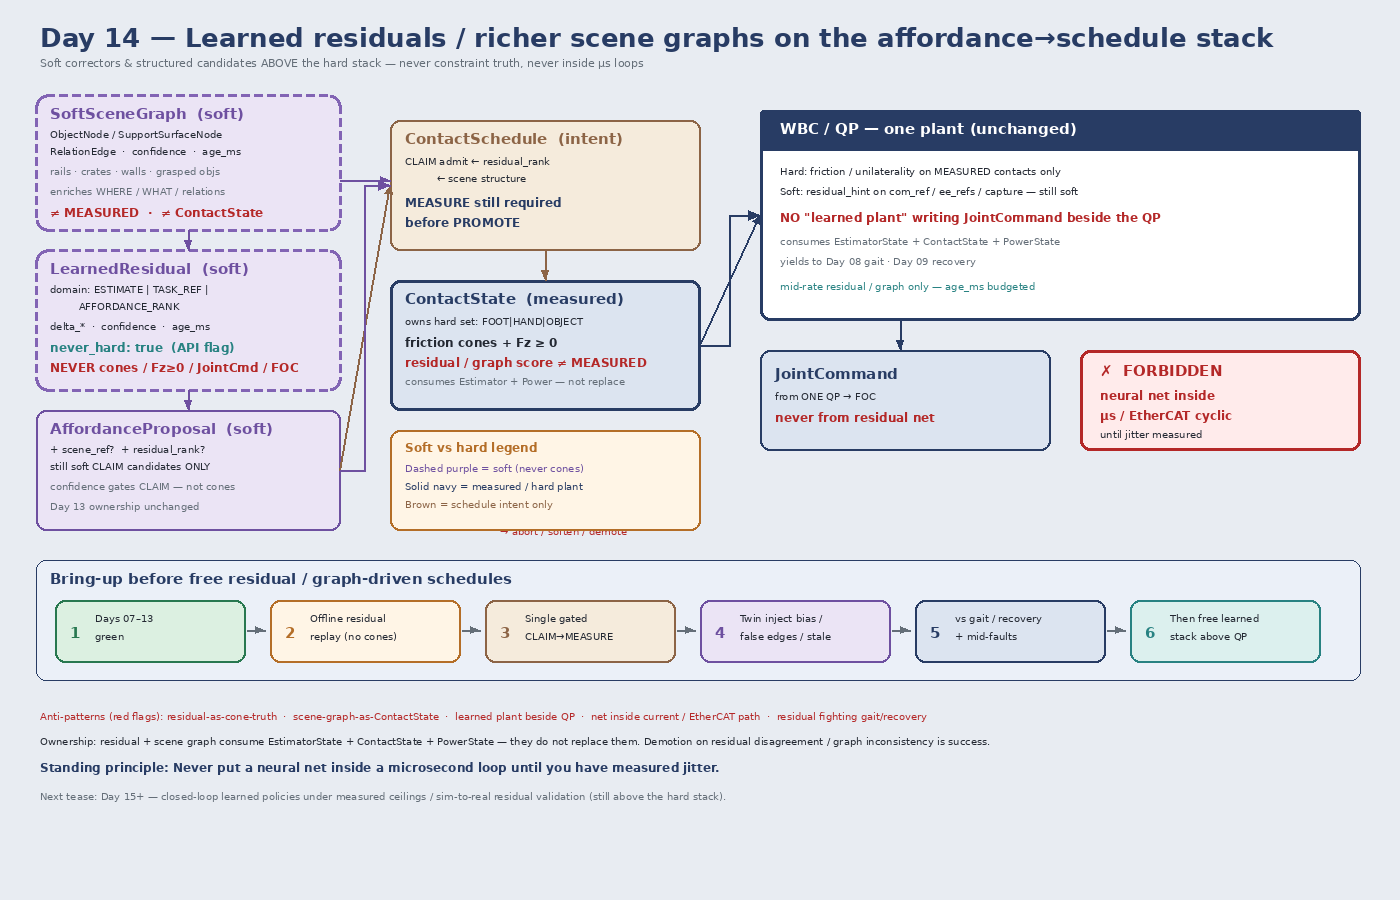
Day 13 owned AffordanceProposal / ContactAffordance as soft CLAIM candidates only: confidence gates CLAIM, not cones; MEASURE required before PROMOTE; detector score MEASURED; measured ContactState owns the hard set; perception never attaches cones, never replaces contact, never writes JointCommand; yields to Day 08 gait and Day 09 recovery. Day 12 owned the ContactSchedule lifecycle and OBJECT kind. Day 11–Day 10 owned measured hand support and soft EE on FREE limbs. Day 09–Day 08 owned recovery abort and gait vs measured contact_set. Day 07 owned the feasible program. Day 06 owned the estimate. Day 05 owned sag honesty.
Today owns learned residuals and richer scene graphs as layers that sit above the hard stack: soft additive correctors and structured candidates into the Day 12/13 affordance→schedule path — not constraint truth, not a second plant, and not inside FOC / rate / QP microsecond loops until jitter is measured and budgeted.
Residuals and scene graphs are soft correctors, not constraint truth
A residual net that writes friction cones, a scene graph that stamps ContactState membership, or an inference path that emits JointCommand beside the QP is detector-as-constraint-truth wearing a larger model. Residuals correct soft features and rank soft candidates. Scene graphs enrich WHERE / WHAT / relations among rails, crates, walls, and grasped objects. MEASURE still admits contacts. Demotion is still mandatory when residual disagreement, graph inconsistency, wrench disagreement, or ceilings fail — including when the net still “believes” the rail is load-bearing.
| Layer | Owns | Must not own |
|---|---|---|
| Learned residual | Soft additive correction on EstimatorState features, soft task refs (com_ref / ee_refs / capture hints), or AffordanceProposal confidence / geometry ranking | Hard friction cones / / JointCommand / FOC / BMS torque_scale override / ContactState membership |
| Scene graph | Structured SoftSceneGraph / ObjectNode / SupportSurfaceNode / RelationEdge feed that enriches affordance generation | Replacing ContactState; attaching cones from graph score; writing schedule phases without CLAIM admit |
| Affordance / perception | Soft AffordanceProposal candidates (WHERE / WHAT / confidence / geometry) — now with scene_ref? / residual_rank? | Friction cones / ContactState / FOC / BMS / gait / recovery truth |
| Contact schedule | Whether a CLAIM slot is allowed given gated proposals + residual/graph ranking; ordered promote / hold / demote intent | Treating residual or graph score as MEASURED; attaching cones from inference alone |
| Measured contact | Membership in hard contact_set (FOOT | HAND | OBJECT) with confidence + wrench agreement | Residual wish, graph edge, or schedule intent as constraint truth |
| Gait (Day 08) | Intended DS/SS/swing clock vs measured feet | Being overridden by a high-confidence residual CLAIM during swing |
| Recovery (Day 09) | Mid-disturbance abort / emergency step | Losing the writer fight to a stuck residual/graph-driven HOLD |
| Soft tasks | EE / grasp / posture on FREE limbs; optional residual_hint soft refs | Parallel “learned plant” writing JointCommand |
| Honesty | Mid-residual / mid-graph CLAIM abort on stale / POWER_GATED / flicker / residual disagreement / graph inconsistency | Heroic completion of a residual-driven handoff into brownout or a false edge |
Core thesis: learned residuals and richer scene graphs consume the same EstimatorState + ContactState + PowerState stack. A LearnedResidual / ResidualCorrection is a soft additive correction (estimate features, soft task refs, or affordance ranking). A SoftSceneGraph / SceneGraphSnapshot enriches AffordanceProposal generation with structured WHERE / WHAT / relations. Both still feed Day 12/13 CLAIM admit as soft candidates. Confidence / residual_rank / graph consistency gates whether a CLAIM is allowed — not whether cones attach. MEASURE is still required before PROMOTE; residual score MEASURED; graph score MEASURED. There is still one QP face — not a “learned plant” that finishes a wall brace because the residual looked sure. Inference runs at mid / host rates with age_ms; never inside the current loop or EtherCAT cyclic write path until jitter is measured and budgeted.
Ownership rule: one writer for residual / scene soft feeds, one writer for affordance candidates, one writer for schedule intent, one writer for measured contact_set. When they disagree, measured contact wins for constraints. Residual confidence and graph score never attach cones. Intent aborts, softens, retimes, or waits — it does not promote OBJECT because the residual ranked a phantom rail first. Day 08 gait and Day 09 recovery still outrank a stuck schedule hold, even when the net is loud.
How today fits the Days 05–13 stack
| Day | What you already froze | What Day 14 reuses |
|---|---|---|
| 05 | torque_scale, POWER_GATED, sag honesty | Same ceilings bind every joint through every residual/graph-driven CLAIM — residual never overrides BMS |
| 06 | EstimatorState, age / stale, contact modes | Residuals may soft-correct estimate features; they do not replace the estimate or erase age faults |
| 07 | Tasks vs hard friction / unilaterality | New contacts join the hard set only when measured — never from residual or graph score |
| 08 | Gait modes vs measured contact_set | Residual/graph CLAIMs must not fight gait clocks; feet stay honest |
| 09 | Mid-event abort / soften; RecoveryCommand | Mid-residual / mid-graph abort; recovery preempts residual-driven holds |
| 10 | Soft EE / grasp; FREE vs CLAIM honesty | CLAIM without measure still forbidden — residual CLAIM included; residual_hint stays soft |
| 11 | MEASURED_SUPPORT hands; LOCO_MANIP | Hands remain first-class; residual may rank hand CLAIM only |
| 12 | ContactSchedule phases; OBJECT kind | Residual/graph feed fills CLAIM slots; schedule lifecycle unchanged |
| 13 | Affordance soft CLAIM; conf gates CLAIM not cones | Scene graph enriches proposals; residual ranks them — detector-as-constraint-truth still forbidden |
Do not bolt a “learned plant” that writes JointCommand or attaches cones beside the QP when residual confidence fires. That is Day 10’s second-plant anti-pattern wearing a GPU.
Residual honesty / rate / jitter gates
Day 13’s pre-CLAIM gate still holds. Day 14 adds residual-domain and rate honesty: residuals correct soft things at mid / host rates with explicit age — never as hard truth inside µs paths.
| Gate | Meaning | Allowed today |
|---|---|---|
| INFER | Host / mid-rate publishes LearnedResidual / SceneGraphSnapshot | Soft only — no schedule phase change yet; no cone attach |
| AGE / JITTER | age_ms within budget; inference not inside current / EtherCAT cyclic | Eligible to influence soft refs or ranking; stale → expire |
| DOMAIN | ESTIMATE | TASK_REF | AFFORDANCE_RANK only | Never HARD_CONTACT / never JOINT_CMD / never TORQUE_SCALE |
| CONF / GEOM / REACH / RANK | Day 13 gates + residual_rank / graph consistency | Eligible to open a CLAIM slot |
| CLAIM | Schedule wants this slot to take weight next | Approach / soft contact seek — no hard cones yet |
| MEASURED | Link in measured contact_set with healthy confidence + wrench agreement | Eligible to promote — residual / graph score does not count |
| PROMOTE / HOLD | Hard friction + attached; soft EE / residual_hint on FREE only | Weight transfer under expanded support |
| DEMOTE | Leave hard set on flicker / stale / gated / residual disagree / graph inconsistency | Soft EE / residual_hint may return only if intentionally FREE again |
Sequencing rules (all required):
- Residual and scene-graph scores gate CLAIM entry and soft ranking — never cone attach.
never_hard: trueis not decoration — API and runtime must refuse residual writes into friction / unilaterality /JointCommand/ FOC /torque_scale/ContactState.- MEASURE still required before PROMOTE; residual score MEASURED; graph score MEASURED.
- Inference runs at mid / host rates with
age_ms; never inside the current loop or EtherCAT cyclic write path until jitter is measured and budgeted. - Residual disagreement with MEASURE / wrench, or graph inconsistency (false edge, missing node, flipped relation) → fail gate or demote — never silently trust the net.
- Mid-sequence
POWER_GATED/ stale / recovery / inference dropout → freeze or abort the schedule; do not advance phases on stale tensors.
Demotion is success when the residual hallucinated support, the scene graph invented a rail–wall edge, or the pack sagged. A robot that always finishes the residual-driven handoff into a collapsing bus is ignoring Day 05 with a prettier training curve.
Scene-graph vs affordance vs measure vs QP ownership
Learned layers are where teams accidentally create a fifth writer on support constraints. Freeze the split:
| Conflict | Winner | Residual / scene / schedule behavior |
|---|---|---|
| Residual score vs missing measure | Measured contact | Wait; soft CLAIM seek only — no cones |
| Graph edge vs missing measure | Measured contact | Drop or never promote; log false edge for twin |
| Residual bias vs MEASURE / wrench disagree | Measured contact + wrench | Demote / fail PROMOTE; residual does not win |
| Scene-graph false edge / missing node | Measured contact (absence or presence) | Expire CLAIM candidates; do not invent membership |
| Stale inference / rate miss | Schedule timing + age gate | Expire by age_ms; never constraint truth from last-known residual |
| Residual fighting soft task refs | Documented soft priority | residual_hint is soft additive — QP still owns feasibility |
Active RecoveryCommand (Day 09) | Recovery | Abort / hold schedule; clear residual/graph-driven CLAIMs if recovery needs feet-first escape |
| Gait swing / touchdown commit (Day 08) | Measured feet + gait owner | Retime or pause residual CLAIM; never steal swing constraints |
POWER_GATED / low torque_scale | Power honesty | Soften / abort; residual never overrides BMS |
| Two residuals / graphs disagree | Single residual+scene / schedule owner | One writer into CLAIM slots; explicit priority — no peer learned plants |
| Residual wants hard cone / JointCommand | Hard stack refusal | Reject at API; log anti-pattern |
Hard vs soft: support constraints on measured FOOT / HAND / OBJECT stay hard. Soft EE and residual_hint authority live only on FREE limbs and soft task refs. Residuals and scene graphs are softer still — they feed ranking and CLAIM, they do not feed cones. If the QP goes infeasible under the expanded set, demote / abort / soften — do not silently drop an object cone so the residual “makes it.”
Mid-residual / mid-graph abort honesty
Learned mid-rate paths are where teams disable safety “just until the batch settles.” Do not.
| Signal mid-CLAIM / mid-residual / mid-graph | Required behavior |
|---|---|
INPUT_STALE / confidence cliff on estimate or contact | Freeze schedule; demote newly promoted contacts that lost confidence; hold safest measured support |
| Inference dropout / host stall / rate miss | Do not promote on last-known residual; expire CLAIM candidates by age_ms |
| Residual disagreement with MEASURE / wrench | Fail PROMOTE or demote; never keep cones the residual invented |
| Graph inconsistency (false edge / missing node / flipped relation) | Re-gate; drop CLAIM or never promote; log for twin |
| Residual bias retract (net flips after CLAIM) | Keep soft seek or demote CLAIM; never keep cones that were never MEASURED |
POWER_GATED / falling torque_scale | Abort remaining CLAIMs / promotes; raise margins; residual never finishes lean into brownout |
| Contact flicker / wrench disagree | Demote that slot to FREE/CLAIM; do not keep cones on noise |
Foot contact_set collapses mid-handoff | Yield to Day 09 recovery; residual schedule is not the escape owner |
| QP infeasible under expanded cones | Demote newest promote and/or drop soft EE / residual_hint — do not drop unilaterality |
| Recovery asserts | Preempt schedule writer; clear or soften MULTI_CONTACT / residual CLAIM hold |
| Residual attempts hard write (cones / JointCommand / torque_scale) | Reject; treat as fault — not as “helpful autonomy” |
Abort, demote, and soften are success paths when the residual hallucinated, the graph lied, or the pack sagged mid-handoff.
Shared API: residual + scene graph into Day 13 affordance shapes
Keep Day 02 / 04 wire honesty. Cyclic commands still carry BusHeader. Extend Day 13 AffordanceProposal / Day 12 ContactSchedule / WbcTaskSet — do not invent a parallel “learned bus” or second plant:
BusHeader:
  node_id, seq
  t_sample, clock_domain, age_budget_ms
  faults

# Upstream (read-only here; residuals may soft-correct features only)
EstimatorState, PowerState  ⊇ BusHeader

ContactState ⊇ BusHeader:
  contact_set[]        # feet, hands, AND objects when measured
  SupportContact:
    link_id / frame
    kind               # FOOT | HAND | OBJECT
    mu, normal, wrench_est?
    confidence, age_ms
    flags              # settling / flicker / gated / grasp_lost
    parent_grasp_id?

# Soft learned residual (host / mid-rate) — NEVER hard
LearnedResidual ⊇ BusHeader:          # or ResidualCorrection
  domain               # ESTIMATE | TASK_REF | AFFORDANCE_RANK
  delta_estimate?      # soft feature deltas only
  delta_com_ref? / delta_ee_refs? / delta_capture?
  residual_rank?       # re-rank AffordanceProposal slots
  confidence
  age_ms               # expire stale inference
  never_hard: true     # API + runtime refuse cones / Fz / JointCmd /
                       # FOC iq / torque_scale / ContactState writes
  relax_on_fault       # stale / dropout / domain_violation → expire

# Soft scene structure (host / mid-rate) — NEVER ContactState
SoftSceneGraph ⊇ BusHeader:           # or SceneGraphSnapshot
  nodes[]:
    ObjectNode | SupportSurfaceNode:
      node_id, kind_hint, pose_hint
      normal_hint? / mu_hint?
      confidence, age_ms
  edges[]:
    RelationEdge:
      src, dst
      relation           # ON | BESIDE | SUPPORTS | GRASPED_BY | ...
      confidence, age_ms
  confidence
  age_ms
  relax_on_fault       # inconsistency / stale → expire candidates

# Soft perception feed — Day 13 + residual/scene enrichment
AffordanceProposal ⊇ BusHeader:
  proposals[]:
    target_frame
    kind_hint          # FOOT | HAND | OBJECT
    pose_hint
    normal_hint?       # soft — not hard cone truth
    mu_hint?
    confidence         # gates CLAIM entry, NOT cone attach
    geometry_ok
    reachability_ok
    residual_rank?     # from LearnedResidual AFFORDANCE_RANK
    scene_ref?         # SoftSceneGraph node / edge id
    age_ms
    source             # VISION | TACTILE | FUSED | RESIDUAL | SCENE | ...
  relax_on_fault

# Thin multi-contact face — Day 12/13 + residual/scene admit
ContactSchedule ⊇ BusHeader:
  intent               # IDLE | MULTI_CONTACT | OBJECT_SUPPORT | ABORT
  slots[]:
    target_frame
    phase              # FREE | CLAIM | PROMOTE | HOLD | DEMOTE
    earliest_t / latest_t?
    priority_hint
    affordance_ref?
    residual_ref?      # which LearnedResidual ranked this CLAIM
    scene_ref?
  yield_to             # GAIT | RECOVERY | POWER
  admit_policy         # min conf / geom / reach / residual_rank /
                       # graph consistency to open CLAIM
  relax_on_fault       # stale / POWER_GATED / flicker / grasp_lost /
                       # residual_disagree / graph_inconsistent /
                       # inference_dropout → abort/demote

ManipulationCommand ⊇ BusHeader:
  intent               # … | CLAIM_SUPPORT | LOCO_MANIP
                       # | OBJECT_SUPPORT | MULTI_CONTACT | ABORT
  ee_refs[] / hand_refs[]
  hand_role[] / support_claim[]
  object_claim[]
  schedule_ref?
  affordance_ref?
  residual_ref?
  scene_ref?
  relax_on_fault

# Extended task face — residual_hint soft only
WbcTaskSet ⊇ BusHeader:
  mode                 # STANCE_DS | STANCE_SS | SWING | IMPACT | RECOVER_IP
                       # | MANIP | HAND_SUPPORT | LOCO_MANIP
                       # | OBJECT_SUPPORT | MULTI_CONTACT | ...
  com_ref / capture_ref?
  residual_hint?       # soft additive on com_ref / ee_refs / capture
                       # NEVER hard constraints
  foot_refs[]
  hand_support_refs[]?
  object_support_refs[]?
  ee_refs[]            # soft EE — FREE limbs only
  hand_refs[]
  posture_bias?
  priority_order[]
  relax_on_fault

JointCommand ⊇ BusHeader:
  q_des? / qd_des? / tau_ff?
  iq_ceiling? / tau_ceiling?
  flags                # STO / soften / hold
Higher layers publish residual corrections, scene structure, affordance candidates, and schedule intent. Measured ContactState owns support membership. Gait and recovery keep their writers. Rate loops enforce BMS ceilings. Nobody re-implements FOC, AHRS, or friction cones inside the residual net or the scene graph.
Physical ↔ digital pairing for residual / scene-driven CLAIMs
| Physical | Digital twin / backing |
|---|---|
Same EstimatorState under changing support membership | No perfect-state residual that always CLAIMs when the net fires |
| Residual bias (systematic soft error) | Twin must inject residual bias; CLAIM without MEASURE never enables cones |
| Scene-graph false edges / missing nodes | Twin must inject false edges and drop nodes mid-CLAIM; expire by age_ms |
| Inference delay / dropout matching hardware age budgets | Matched delay / rate-miss budgets — soft timing only; never constraint truth |
| Residual vs MEASURE disagreement | Injected disagreement; fail PROMOTE / demote proven |
POWER_GATED during residual-driven CLAIM | torque_scale replay — no infinite-torque brace on a residual-ranked rail |
| Residual fighting gait / recovery | Twin must show yield/retime/abort — not silent override |
| Mid-rate residual + scene + schedule tick + jitter | Cannot beat hardware cadence or hide age faults; no net inside cyclic write path |
If the twin always promotes when the residual ranks a slot with sticky contacts and a full pack while hardware sees biased residuals, false edges, delayed inference, and sag, you will tune learning rates forever and never ship a CLAIM that survives a tired bus or a hallucinated rail.
Bring-up sequence (before free residual / graph-driven schedules)
Days 07–13 green (stance, step, recovery, FREE-hand reach, measured hand SUPPORT / loco-manip, scripted multi-contact / OBJECT handoffs, gated affordance CLAIM with false+/miss/delay/wrong-normal proven). Then:
- Days 07–13 green — affordance admit + schedule abort paths still behave; no open recovery or gait fights; OBJECT / HAND promotes still require MEASURE; detector-as-constraint-truth still impossible.
- Offline residual / scene replay — replay logged residuals and scene snapshots into soft refs and CLAIM admit only; confirm high residual_rank without MEASURE never attaches cones; confirm domain violation (
never_hard) is refused; confirm staleage_msexpires candidates. - Single live gated residual/scene CLAIM — one known surface or fixed object; scene graph + residual rank propose → gate → CLAIM → wait for MEASURED → PROMOTE → HOLD → DEMOTE; feet remain primary; confirm QP feasible; confirm
residual_hintstays soft. - Learned honesty injects — residual bias, scene-graph false edges / missing nodes, inference delay / dropout, residual-vs-MEASURE disagreement,
POWER_GATEDmid-CLAIM in twin and on hardware; confirm drop / wait / demote, not heroic promote-on-score. - Non-fight + mid-residual / mid-graph faults — force residual-CLAIM-during-swing, recovery-during-HOLD, stale / gated / flicker / graph inconsistency / residual disagreement; confirm yield / abort / demote.
- Then add free residual / scene-driven schedules that choose ranking / soft refs above the QP — never replace cones, FOC,
torque_scale, gait, recovery, or measuredContactState. Closed-loop learned policies under measured ceilings and sim-to-real residual validation continue in Day 15.
Skip to “end-to-end learned multi-contact in sim” and hardware’s first residual-ranked rail grasp becomes an unplanned tip / brownout experiment with better TensorBoard.
Failure gallery
| Symptom | Likely cause |
|---|---|
| Promotes on air / tips toward residual-ranked phantom | Residual / graph score treated as MEASURED; cones without contact_set |
| Twin CLAIMs, hardware faceplants | Perfect residuals / no false edges / infinite torque_scale in sim |
| Completes residual lean into brownout | Mid-CLAIM abort missing; ceilings not consulted; residual overrode honesty |
| Net “wins,” foot slips | Soft EE / residual_hint treated as hard; unilaterality dropped |
| Scene-graph edge invents OBJECT membership | Graph score trusted as ContactState without MEASURE |
| Residual vs MEASURE disagree → still HOLD | Disagreement demote path missing |
| Stale tensors keep CLAIMing | Residual / scene age_ms / dropout expire missing |
| Second plant for residual brace | Parallel optimizer / policy writing JointCommand; fights Day 07 program |
| Net inside current / EtherCAT cyclic | Jitter never measured; standing principle violated |
Residual overrides torque_scale | BMS honesty broken; never_hard not enforced |
| Schedule freezes loaded sole for residual pose | Intent / residual owns foot constraints instead of measured feet |
| QP infeasible → silent cone drop | Demote/abort path missing; “make it feasible” anti-pattern |
| Gait / recovery fights residual CLAIM | Multiple writers on WbcTaskSet / mode; no arbiter |
| Swing stolen by residual rail CLAIM | Schedule did not yield to Day 08 gait commit |
| Net learns only on sticky perfect graphs | Residual trained without bias / false edges / delay / disagreement / sag |
What to freeze this week
Extend frames and your control config with:
LearnedResidual/ResidualCorrectionfields:domain, softdelta_*,residual_rank,confidence,age_ms,never_hard: trueSoftSceneGraph/SceneGraphSnapshot:ObjectNode/SupportSurfaceNode/RelationEdge, confidence,age_ms— soft onlyAffordanceProposalextensions:scene_ref?,residual_rank?WbcTaskSetoptionalresidual_hint— soft additive on FREE / soft refs only- Who owns residual / scene soft feeds vs affordance candidates vs ContactSchedule intent vs measured
contact_setvs gait vs recovery (disagree → wait/yield/demote; measured contact wins for cones; recovery and gait outrank schedule holds) - Admit policy: confidence / geometry / reachability / residual_rank / graph consistency gate CLAIM, never cone attach
- Explicit rule: residual score MEASURED; graph score MEASURED; learned layers never write
JointCommand, friction cones, FOC , ortorque_scale - Rate / jitter budget: residual + scene inference at mid / host rates with
age_ms; forbidden inside µs / EtherCAT cyclic until jitter measured - Mid-residual / mid-graph abort / demote for stale,
POWER_GATED, lowtorque_scale, flicker, residual disagreement, graph inconsistency, and inference dropout - Twin hooks: residual bias, false edges / missing nodes, inference delay / dropout, residual-vs-MEASURE disagreement,
POWER_GATEDmid-CLAIM, residual-vs-gait/recovery fights — same as hardware - Bring-up gate: no free residual / graph-driven multi-contact until steps 1–5 above are green
The lesson is not “drop a bigger net on the robot until the reward looks busy.” It is make learned residuals and richer scene graphs the same contact-rich program in silicon and in the twin: soft correctors and structured candidates into affordance→schedule CLAIM slots, ranking gating entry not cones, one estimate, honest power ceilings, measured FOOT/HAND/OBJECT in the hard support set, schedules that wait for measurement and yield to gait/recovery, soft tasks / residual_hints only where soft belongs, inference outside µs loops until jitter is honest, and abort / demote paths that stay honest when the residual or the graph lies mid-CLAIM.
Next
Day 15 — Closed-loop learned policies under measured ceilings / sim-to-real residual validation: policies that act only through soft refs and schedule candidates above the same measured hard set — still no learned-plant-as-constraint-truth; twin must keep residual bias / false edges / delay / disagreement / sag honesty + sim-to-real residual validation before free closed-loop learned multi-contact.